Friday, April 8, 2016
MindControl 1.0 for Python
Sunday, June 28, 2015
GT Crawler
As opposed to my previous off-roader, the Red Raccoon which has occupied my desk for good three months through at least five versions, this time I've had a clearer picture what I'm aiming at, therefore this GT Crawler required "only" two weeks.
Let's begin with mechanical stuff. The intention was, among other things, to try out a combined suspension and direct-to-wheel drive. Typically, a large share of off-roaders features either a free-axle suspension or trailing arm design. The weakness of the former is that the turning axis of the front wheels changes as the chassis rises and sinks, while the latter offers, depending on the type, weak wheel independence or complex construction. This time I've tried combining these: each pair of wheels is built on a pendular axle, which is in turn connected to a large trailing arm via a turntable. The chassis is, of course, in between, along with its recentering mechanism so that the bodywork doesn't freely tilt in the curves. Since the trailing arms have been designed to offer a very large travel, there was a lot of spring required ― as much as ten were required to keep the chassis in balance (not sunk to the bottom neither forced up to the top).
The other concept regards the drive; each wheel is connected directly to its own PF Medium motor, without any U-joints, gears or transmissions, in order to keep the mechanical losses to the minimum. This, of course, is a trivial task at the rear, but is quite a challenge at the front wheels because the motors need to turn along with the wheels during steering, implying adventures with the cables as well as a very specific construction that requires lots of room for the moving motors (which at 6x3x3 studs aren't small). And furthermore, find some more space for a PF Servo and keep everything stiff, unfortunately reducing the ground clearance somewhat. The two battery packs are placed at the sides of a rather small chassis root, and right above them, three *PF IR receivers: two for the motors (on the same channel, each pack runs its two wheels), and another one for the headlights.
The bodywork, apart from the headlights as the only "function", serves no other purpose than a decorative one: the chassis can be driven just as well without it. Unfortunately, various reinforcements and PF elements in the middle eliminated any possibility of a nice interior, but that was not too much of a trouble because that would only increase the weight of an already not too light 1.9 kg. Dimensions are 48x28x24 studs, therefore very close to the 9398 4x4 Crawler (GT is slightly lower, wider and about a quarter of a kilogram heavier).
GT Crawler drives and handles pretty fine. Although the PF Medium motors don't offer a serious torque making this car unable to climb steep hills, it is compensated by excellent torque distribution and a good maximum speed. More of a SUV than a crawler in that respect, then. The only drawback of this design is that the batteries in the packs need to be very close in charge, because any small differences in the torque on either side make the crawler slightly turn towards the weaker side if driven straight. (The option to split batteries on front and rear ends instead of the sides showed to be too complex, and would also discharge the packs unevenly through time.)
GALLERY
GENESIS
YOUTUBE
Saturday, November 1, 2014
70816 Benny's Spaceship Review: A Flashback in Blue
I know this is primarily a Technic/Mindstorms site, but I like Classic Space as well ― as do many AFOL's in their mid-thirties nowadays. And so I just couldn't resist buying an official neo-Classic Space set that has recently been launched along with the Lego Movie: a 70816 "Benny's Spaceship, Spaceship, SPACESHIP!". It consists of 903 pieces and is by far the largest ever set in the Classic Space department. It's actually, in terms of part count, the second largest set in the overall Space family, not counting the Star Wars monsters. Despite the name, this set actually consists of two craft.
Design is a very personal thing, and while this spaceship perhaps isn't as elegantly streamlined as other LEGO starships of the post-classic era, it is supposed to be a remake of the Classic Space, and I find it very faithful to its design principles that focus on function rather than spectacular looks. As one would expect from a Neo-Classic, it is mostly blue-grey, with a trans-yellow cockpit canopy. The secondary craft is more of a Blacktronesque thing, certainly more modern, and its black-red theme works nicely, too.
The Big Blue has also a handful of features: openable cockpit with three minifig seats, openable mid-section, rotatable dish antenna in the rear, and ― the main party piece ― wings that can extend outwards, thus freeing the room for twin rocket launchers otherwise concealed in the hull to shoot. This is done cleverly by pushing the rear rocket, which in turn widens the wings using Technic beams inside. There are also smaller "Antenna" shooters, based on part 15301c01.
In the middle compartment there are extra seats, some tools and a power generator (a reactor of sort?) is visible in the rear behind the window, which is pretty cool. In the rear there are two droids with their auxiliary equipment. Despite being neat, I have a slight feeling that the front of the ship could have held some more functionality than openable cockpit. But perhaps I'm just spoiled. There are two small, detachable ships at the ends of the wings. They have to flip one wing upwards to allow connection to the mothership, and it is nice that everything is symmetric, so both mini-ships fit on both wings. They can carry one minifig each. The smaller ship offers an openable canopy for its one-man cockpit, and that's about it, though one could hardly conceive of more functionality crammed into this small craft.
While it doesn't suffer from any construction issues, I found the large ship somewhat fragile. Not its hull, which is fairly strong and sturdy, but rather plenty of details such as wings, missile launchers or the dish antenna, that need the slightest of forces to detach. It's fine for playing on the table top, but I guess waving it around may result in some (fortunately, repairable) damage.
Both ships are fun to build, and personally I've been positively surprised by the amount of hidden Technic parts and the clever way they are used to allow the ship to be built in steps, yet effortlessly connected together when everything is done. A bit of Technic is responsible also for the wing-extending mechanism.
At over 900 parts, this is a good parts supply set, and actually the only one available if you intend to build Neo-Classic yet prefer to buy new. A nice cockpit canopy, launchers, lots of bricks and technical details that are useful everywhere, arches and wedges, and many other fine parts are included here. There are five minifigs, all from the movie ― four humans (or humanoids?) and the Astro Kitty. Benny, the Neo-Classic pilot, with his worn-off chest logo and a simulated crack on the helmet, is a clever tongue-in-cheek reference, especially to the old helmets that really are prone to breaking. (I must have broken at least a third of mine at the time.)
PROS & CONS
+ Good parts supply for Neo-Classic Space
+ Fun to build and play with
+ Lots of nice details
+ Interesting building techniques, especially extendable wings
- Somewhat fragile
- A bit short on functionality at the front
VERDICT
Among the largest and coolest Space sets LEGO has ever released, particularly as a true flashback to the Classic Space days with a sense of humour. But it is fun to play with as well, though one could imagine this is a set likely to be bought by many AFOL's and shall either be used as an exotic new parts supply, or a display piece for the living room shelf.
Monday, February 17, 2014
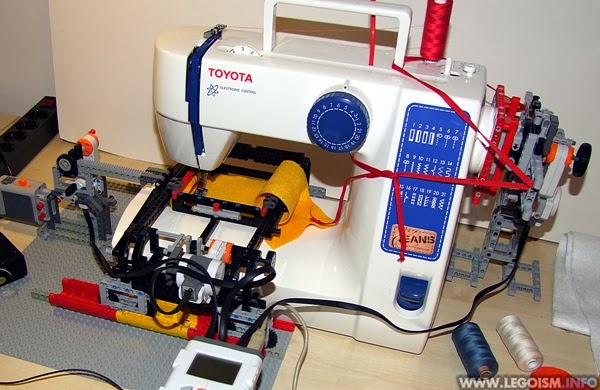
NXT Embroidery Machine
"What the heck is that?" is a perfectly normal response to seeing the Frankensteinian thing on the photo above ― especially if you are a LEGO purist, as the non-LEGO parts outweigh the bricks easily by 5:1 ratio, perhaps even closer to 10:1.
There are professional embroidery super-machines that operate with multiple colours simultaneously and can quickly embroider on anything up to a tank armor, but going small and simple, the main difference to the hobby sewing machines is 2D movement control of the fabric (as opposed to linear step movements) and control of the needle, via the master handwheel. That takes three motors, exactly as many ports NXT 2.0 offers.
While two NXT motors move the fabric beneath the needle, the third one controls stitching by rotating the handwheel. As primitive as it sounds, this was actually by far the most challenging component that took over ten failed versions to get right. Firstly, the handwheel is very smooth and difficult to get a mechanical grip on (at least on the Toyota JFS21 I've used) ― the final mechanism actually rotates it by pushing a switch on its side. Rubber bands were out of the question as the revolutions need to be precise in the long run.
Secondly, the torque required to rotate the wheel occasionally rises beyond 1 Nm, especially when stitching very densely. This is beyond what an NXT motor can provide and requires a strong gearbox, lots of reinforcements and puts plenty of strain on the driving mechanism ― I've actually destroyed a couple of 3/4 pins pushing the machine wheel before I settled with a solution using a stop pin. And even with sevenfold gearing down, the motor obviously struggles at times.
Software running these motors is rather simple ― it moves the fabric to a desired location, does a full wheel turn, and repeats these two steps until all the stitch points are exhausted. They are imported as numerical data from a CSV generated by a handy application EmbroiderModder which can, in turn, import data from various other formats, embroidery programs, stitching clipart, etc. When sewing in multiple colours, the program stops and allows the user to change the thread on the sewing machine and resume by tapping an NXT push sensor.
And the results? Satisfactory, though by no means perfect. As mentioned before, this machine struggles with dense stitching (though I've seen reports that cheap embroidery machines do too), and the accuracy is often insufficient for very small and detailed, precise designs, e.g. text smaller than a few millimeters in height. Also, it asks for patience: stitching a typical design (say, a thousand sewing points) takes about an hour, so forget about mass production. An hour of loud NXT motor whining, that is. There is of course some more time required to find and prepare the stitching sequence.
However, it turned out to be pretty reliable and perfectly adequate for hobby stuff and making simple custom-embroidered shirts. There's something satisfying in the fact that the combined prices of this sewing machine and a full NXT set are less than a half of what a standard-issue home embroidery machine costs, regardless of its advantages.
A hypothetical future version 2.0 would probably take advantage of the embedded sewing machine motor which is significantly more powerful than anything in LEGO arsenal ― controlling its throttle pedal and measuring the real turns of the wheel, probably with a colour sensor and a piece of a coloured tape glued to the wheel off-center. More complicated and likely less reliable, but a lot faster.
T-shirts with a Classic Space logo (intentional rusty old look, as on the photo) now finally seem a much more realistic wish!
DOWNLOAD
You can download the source files I've used for this project here. However, the parameters supplied within are applicable for my rig ― and if you decide to build your own, you will probably need to adjust them anew, since the rig design depends heavily on the sewing machine being used.
VIDEO
Monday, December 30, 2013
MILSGen
Assisting on a side project, I've put together a program named MILSGen that may help designing and building large, geographically accurate LEGO dioramas. It takes an image representing an elevation map, and splits it down to an array of corresponding MILS modules 32x32 studs in size. In case you haven't heard of it yet, MILS is a concept of creating large landscapes using pre-built modules that can be easily transported and quickly connected using regular Technic pins. (Find more about MILS system on the webpages of Antonio BellĂłn, who developed and wrote a detailed article about it.)
It is a simple text application that lets the user choose an input image, where each pixel corresponds to a single stud at the output. Then, it solves the given terrain segment using several common LEGO plates, trying to keep it as "hollow" as possible to reduce the overall weight and part count. Finally, the standard underlying MILS structure is added, and each module exported into LDraw format one can view in LDView, edit via MLCad, etc.
There are some additional features: it automatically crops the input image to the maximum size that can be created with 32x32 tiles, covers the outside structural edges with closed bricks, lets the user choose the physical height of the highest point of the input image, and even to omit the entire substructure altogether if the overlying terrain is all one needs.
In addition, to simplify the finaly assembly, one can enable the edge identifiers that put a set of 1x1 bricks at each inner edge, which matches its exact unique pair on its neighbour. The modules are named according to their coordinates in the entire system, borrowing the chess system: letters and numbers indicating columns and rows, respectively. E.g. top left corner is A1, third row in fourth column is D3, etc.
What MILSGen doesn't do are reinforcements. Since I wanted to finish it before the year 2400, structural analysis was out of the question; it is down to the builder of MILS modules to judge where are the reinforcements necessary, and in what amount. Also, it doesn't process input colors but just the pixel brightness: the entire output landscape is green. Acquiring an additional image with colour map and approximating it to a palette of common LEGO colours might be implemented in some of the future versions.
Installation is really simple ― just download the ZIP, unpack everything to a new folder, copy your input image there as well, and run the executable. It's not particularly pretty but it serves its purpose. Make sure to check out the PDF with detailed instructions, prerequisites for the input files and some other remarks included in the ZIP file, or separately available here as well.
Sunday, August 11, 2013
NXT Auto-Engraver Prototype
Typically, the main raison d'ĂȘtre of my LEGO projects is fun, but this one was actually ignited by a specific task that occured, initially unrelated to LEGO: the aim was to engrave a given digital bitmap on a flat surface of a few plastic objects. Sounds like a job for NXT & Technic duet, doesn't it?
Some time ago I've attempted to build an entire NXT CNC for plastic with an electric drill and everything, and it turned out just a tad over-ambitious. This time the basic concept would remain the same ― that is, a vertical rotating drill bit which moves in 3D above the engraved surface. However, this time the mechanical requirements were significantly lower, and the machine doable using fairly regular techniques and parts. The intention was actually to build a prototype as a proof of concept (which explains its ugliness, kludges and devilish colour-clashing), and make a final, finely designed and engineered engraver afterwards, if it turns out to be used regularly.
The drill bit is a standard diamond-coated one used for engraving, and as such the only part which is not LEGO. It is driven by a PF XL and M motors running through and adder to reach sufficient rotation speed without sacrificing the torque, and this structure can be moved vertically with four gear racks and 12T gears, rotated by the first NXT motor. This whole mechanism is suspended on a frame which slides on four rails built using tiles and Technic bricks, and is moved by a pair of large linear actuators running in parallel. The actuators were an obvious choice thanks to their high precision, whereas the vertical movement of the drill is not as critical, since it pushes into the surface to be engraved with the entire weight of the structure anyway.
The Y dimension is regulated by moving the object itself, again on a rail built with tiles and Technic bricks, and moved by a linear actuator ― but this time one was sufficient. The entire extents of the actuators can be used, resulting in an engraving area of slightly over 5x5 studs (40x40 mm), which is more than enough for the objects in question. They are held in place using cradles built from Technic bricks, and secured in place with stop pins. A couple of them simultaneously easily keep the object in place while the drill does its job.
To speed up and simplify the tedious task of rotating the actuators by hand while moving the drill to a desired starting point, I've added two PF L motors, each of which can be engaged to the actuators' driveshafts when needed using the standard gearbox driving rings, operated manually. In addition, the entire drilling structure can be lifted sideways to allow access to the cradle and the object, and also to change the drill bit if necessary.
The NXT script is very simple ― it reads the movement instructions from an onboard text file. This file is beforehand generated by a short Python program I've made for the purpose, which opens a desired image file, simply rounds it to white and black pixels, and then generates and uploads the file on the Smart brick. It uses a simple scanning algorithm (left-to-right in each line, and each line top-to-bottom) to provide as consistent and precise movements as possible, reduce gear whiplash effects, axle tensions, etc.
All in all, the machine works pretty well. While obviously not engraved on professional equipment, the result was fairly satisfactory and its resolution was even better than I had skeptically expected. For a moderately complex logo about 20x8 mm in size it took about ten minutes, and with some movement optimizations I haven't taken the trouble for in this prototype phase, I'm sure this could be reduced down to about six or seven. Of course, some kind of external power supply is mandatory for mass engraving (which is underway at the time of writing).
A FEW MORE PHOTOS
SHORT VIDEO
Tuesday, May 21, 2013
Having fun at the nearby lake
I'm well aware that working, remotely controlled Technic boats based on compact LEGO hulls have already been confirmed as a working concept, but I just couldn't help giving it a little try myself, in the catamaran layout. Nothing extremely developed or fancy ― the intention was to just have some fun testing it at the nearby lake.
It turns out that this design works rather well, and the boat was both swift when running under full throttle, and maneuvrable. Instead of having a drive & rudder motor configuration, it actually uses two parallel propellers, each connected to its independently controlled Power Functions L motor*. Turning is, just like a tank, done by turning the propellers at different speeds, or in the extreme case, turning them in the opposite directions (i.e. a differential drive). They are controlled by an IR V2 receiver and powered by a standard battery pack.
The boat was pretty stable and did not rock too dangerously even when maneuvering rapidly. Design allows the battery pack to be mounted at several points longitudinally (along a Technic liftarm), so that the overall balance of the boat could be finely adjusted in the center. It turns out I was lucky, and the initial configuration from the workbench was already working well.
What wasn't working so well were the propellers which had the tendency to collect every bit of weed floating around the lake and get stuck, and the IR controls which struggled with the intense sunlight, reducing the control range to just barely a meter or two. Of course, in theory an NXT smart brick could be used instead, which offers the extended range of Bluetooth communication, but I simply didn't want to risk ruining it in the water if anything went wrong. Fortunately, it didn't anyway, and the boat actually easily handled some extra weight of a GoPro camera.
In any case, it is not too difficult to build (just make sure it's sturdy and simple), and the hulls can be found on BrickLink for reasonable prices, so give it a try if you feel like a LEGO Captain!
GALLERY
VIDEO
* Thanks to Sariel for the transmission idea